

Every year, the team designs, builds, and programs a different robot, prepared to overcome the challenges set out in the Eurobot competition.
2026
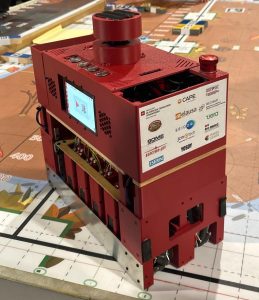
Garrinator XIII
In 2026, we opted for this robust and modular design with the goal of being able to reuse its base each year for new challenges. That year, all our robots were 3D printed with PETG to provide them with greater impact resistance and to reduce material waste. Furthermore, to achieve even greater robustness, this aluminum plate and wooden base have been incorporated.
To facilitate future maintenance, scalability, and efficiency, ROS2 has been used following SOLID principles, utilizing C++ for greater speed and efficiency, and Python for easier maintenance.
Thanks to this gripper design with an integrated color sensor and the Mecanum wheels, we can grab and rotate all 4 pieces simultaneously in a fast and efficient manner, moving unidirectionally while doing so.
Garrinator XII
Omnidirectional autonomous robot with integrated ROS2, capable of detecting obstacles and accurately positioning itself across the field.
Built with a combination of 3D-printed parts, aluminum sheets, and wood, which give it robustness and versatility.
It incorporates an advanced actuator with telescopic guides, controlled by two stepper motors and equipped with inverted electromagnets, which allow it to accurately and reliably grasp magnetic material from the field.
2025

2024

Garrinator XI
Autonomous differential robot with integrated ROS1, capable of detecting obstacles and reacting with agility thanks to its brushless motors.
Its structure combines 3D-printed parts with wooden and acrylic sheets, achieving a design that is both robust and versatile.
It incorporates a unique actuator: a double turret/revolver controlled by stepper motors, equipped with contact and presence sensors that allow it to interact with the environment with precision and reliability.
Garrinator X
Omnidirectional robot with three omniwheels, designed to store and manipulate plastic discs of different colors and construct a three-disc tower with a specific chromatic pattern.
Equipped with stepper motors for both the wheel movement and the control of the manipulator arm.
The arm has three degrees of freedom, can move to any position in the XY plane, and also move up and down using guides with a belt system.
The end effector incorporates three small suction cups with a solenoid valve that allows the discs to be held by suction and placed with precision.
2023

Image gallery of the other robots created over the years by the team


